


1.创建矩阵
#include
#include using namespace std;
using namespace Eigen;int main()
{MatrixXd A(6,4);//6*4的矩阵A << 1, 2, 3, 4,   //用A<<赋值,“,”作为分隔符1, 4, 3, 2,1, 3, 2, 4,4, 1, 1, 3,2,3,5,4,1,2,5,9;cout << A << endl;
}
- 求解线性方程组AX=B(最小二乘)
#include
#include using namespace std;
using namespace Eigen;int main()
{//线性方程求解 Ax =B;  MatrixXd A(6, 4);A << 1, 2, 3, 4,1, 4, 3, 2,1, 3, 2, 4,4, 1, 1, 3,2, 3, 5, 4,1, 2, 5, 9;cout << A << endl;MatrixXd B(6, 1);B << 12, 56, 23, 15, 12, 35;Vector4d x1 = A.colPivHouseholderQr().solve(B);cout << x1 << endl;
}
- 矩阵按索引调用格式(和MATLAB一致,索引从0开始)
A(3,2)//A矩阵的4行3列
A(3,2)=1//给A矩阵4行3列处赋值
A.size()//返回矩阵大小
A.rows()//返回矩阵行数
A.cols()//返回矩阵的列数
A.row(1)//返回矩阵的第二行数据
A.col(1)//返回矩阵的第二列数据
A.resize(m,n)//重塑A矩阵的行列,如果已经矩阵大小固定,则无法进行
- 矩阵取最大值最小值及索引位置
#include
#include using namespace std;
using namespace Eigen;int main()
{MatrixXd A(6, 4);A << 1, 2, 3, 4,1, 4, 3, 2,1, 3, 2, 4,4, 1, 1, 3,2, 3, 5, 4,1, 2, 5, 9;MatrixXd::Index maxrow, maxcol;MatrixXd::Index minRow, minCol;int max_num = A.maxCoeff(&maxrow, &maxcol);int min_num = A.minCoeff(&minRow, &minCol);cout << "max value=" << max_num << "  rows=" << maxrow << "  cols=" << maxcol << endl;cout << "min value=" << min_num << "  rows=" << minRow << "  cols=" << minCol << endl;
}
5.矩阵运算
+ -   +=  -=   *   /   *=   /=  -A//(矩阵取负)
A*A//矩阵相乘
A*vector//矩阵向量相乘
MatrixXd A = MatrixXd::Random(6, 6);//随机生成6*6测试矩阵
A.fill(10);//矩阵填充
m1=( Matrix3f(rows,cols)<<1,2,3,4,5,6,7,8,9 ).finished(),//矩阵后添加数据
- 矩阵操作操作
A.transpose() //矩阵转置
A.conjugate()//共轭矩阵
A.adjoint()//伴随矩阵
A.determinant()//矩阵的行列式
A.diagonal();//对角阵
R = P.cwiseProduct(Q);    // R = P .* Q
R = P.array() * s.array();// R = P .* s
R = P.cwiseQuotient(Q);   // R = P ./ Q
R = P.array() / Q.array();// R = P ./ Q
R.cwiseInverse();         // 1 ./ P
R.array().inverse();      // 1 ./ P
R.array().sin()           // sin(P)
R.array().cos()           // cos(P)
R.array().pow(s)          // P .^ s
R.array().square()        // P .^ 2
R.array().cube()          // P .^ 3
R.cwiseSqrt()             // sqrt(P)
R.array().sqrt()          // sqrt(P)
R.array().exp()           // exp(P)
R.array().log()           // log(P)
R.cwiseMax(P)             // max(R, P)
R.array().max(P.array())  // max(R, P)
R.cwiseMin(P)             // min(R, P)
R.array().min(P.array())  // min(R, P)
R.cwiseAbs()              // abs(P)
R.array().abs()           // abs(P)
R.cwiseAbs2()             // abs(P.^2)
R.array().abs2()          // abs(P.^2)
**给一个已经存在的矩阵后面增加一行:**
MatrixXf s(3,4);
s<<1,2,3,4,5,6,7,8,9,10,11,12;
s = (MatrixXf(4,4)<
7.矩阵块操作
A.block(i,j,p,q);//返回从矩阵的(i, j)开始,每行取p个元素,每列取q个元素所组成的临时新矩阵对象,原矩阵的元素不变
A.block(i,j);//返回从矩阵的i行,j列的一个新矩阵
8.向量的块操作
获取向量的前n个元素:vector.head(n);
获取向量尾部的n个元素:vector.tail(n);
获取从向量的第i个元素开始的n个元素:vector.segment(i,n);
9.向量操作
A.dot()//向量点积
A.cross()//向量叉积
A.norm()//向量范数
A.normalization()//向量归一化
A.normalized()//向量的每个数除以这个向量的范数
A.normalize()//作用和normalized()是一样的,区别在于,normalized()是产生一个临时矩阵,而这个是直接对原矩阵进行变换。
A.reserve()//向量顺序取反
矩阵和向量的混合操作:VectorXd ind(5);MatrixXd matrix(5,5);matrix << 1, 2, 3, 4, 5,4, 5, 6, 7, 8,7, 5, 4, 5, 2,1, 4, 7, 8, 5,1, 2, 3, 6, 5;ind << 1,2, 3,4, 5;cout << matrix.rowwise() + ind.transpose() << endl;//行相加***************************cout << matrix.colwise() + ind << endl;//列相加***************************cout << matrix.array().rowwise()*(ind.transpose()).array() << endl;//行向累乘***********cout << matrix.array().colwise() / (ind.array()) << endl;//列向累除**********************
10.一维Vector转为矩阵或者向量
#include
#include
#include
using namespace Eigen;
using namespace std;
int main()
{vector x;//注意vector中元素的类型double与矩阵类型matirxX(d)一致for(double i = 0; i < 10.0; i++){x.push_back(i);}MatrixXd re = VectorXd::Map(&x[0],x.size());//转化成矩阵//VectorXd re = VectorXd::Map(&x[0],x.size());//转化成向量system("pause");return 0;
}
- 行列顺序
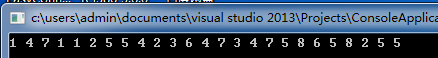
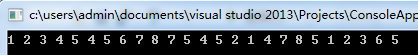
Matrix matrix;//列为主//Matrix matrix;//行为主matrix << 1, 2, 3, 4, 5,4, 5, 6, 7, 8,7, 5, 4, 5, 2,1, 4, 7, 8, 5,1, 2, 3, 6, 5;ind << 1,2, 3,4, 5;for (int i = 0; i < matrix.size(); i++){cout << *(matrix.data() + i) << " ";}cout << endl;
列为主:
行为主:
12. 矩阵,向量,行,列,向各个方向复制
(matrix.row(4)).replicate(4,1)//第五行复制四行一列
matrix.replicate(4,1)//第矩阵复制四行一列
13.数组转矩阵或向量
	int array[8];for (int i = 0; i < 8; ++i) array[i] = i;																	MatrixXi aa = Map >(array);//将数组array转化为两行四列,且以行为主的矩阵可简写为:MatrixXi aa = Map(array);VectorXi bb = Map(array,8);//将数组array转化为向量,8表示0:8个值VectorXi bb = Map(array+3,8);//将数组array转化为向量,只取第4个到第8个VectorXi bb = Map >(array+3, 2);//将数组array转化为向量,从第4个开始,步长为3,取两个//*********************************************************************************************************
int array[12];
for(int i = 0; i < 12; ++i) array[i] = i;
cout << Map >(array, 3, 3, OuterStride<>(4)) << endl;//转化为列主矩阵,3*3,且步长为4的矩阵
结果:
0 4 8 1 5 9 2 6 10
参考链接:
写了半天发现别人写的更全----------------------
转载链接https://blog.csdn.net/hurmean/article/details/70143723
内容:
// A simple quickref for Eigen. Add anything that's missing.
// Main author: Keir Mierle#include Matrix A;               // Fixed rows and cols. Same as Matrix3d.
Matrix B;         // Fixed rows, dynamic cols.
Matrix C;   // Full dynamic. Same as MatrixXd.
Matrix E;     // Row major; default is column-major.
Matrix3f P, Q, R;                     // 3x3 float matrix.
Vector3f x, y, z;                     // 3x1 float matrix.
RowVector3f a, b, c;                  // 1x3 float matrix.
VectorXd v;                           // Dynamic column vector of doubles
double s;                            // Basic usage
// Eigen          // Matlab           // comments
x.size()          // length(x)        // vector size
C.rows()          // size(C,1)        // number of rows
C.cols()          // size(C,2)        // number of columns
x(i)              // x(i+1)           // Matlab is 1-based
C(i,j)            // C(i+1,j+1)       //A.resize(4, 4);   // Runtime error if assertions are on.
B.resize(4, 9);   // Runtime error if assertions are on.
A.resize(3, 3);   // Ok; size didn't change.
B.resize(3, 9);   // Ok; only dynamic cols changed.A << 1, 2, 3,     // Initialize A. The elements can also be4, 5, 6,     // matrices, which are stacked along cols7, 8, 9;     // and then the rows are stacked.
B << A, A, A;     // B is three horizontally stacked A's.
A.fill(10);       // Fill A with all 10's.// Eigen                            // Matlab
MatrixXd::Identity(rows,cols)       // eye(rows,cols)
C.setIdentity(rows,cols)            // C = eye(rows,cols)
MatrixXd::Zero(rows,cols)           // zeros(rows,cols)
C.setZero(rows,cols)                // C = ones(rows,cols)
MatrixXd::Ones(rows,cols)           // ones(rows,cols)
C.setOnes(rows,cols)                // C = ones(rows,cols)
MatrixXd::Random(rows,cols)         // rand(rows,cols)*2-1        // MatrixXd::Random returns uniform random numbers in (-1, 1).
C.setRandom(rows,cols)              // C = rand(rows,cols)*2-1
VectorXd::LinSpaced(size,low,high)   // linspace(low,high,size)'
v.setLinSpaced(size,low,high)        // v = linspace(low,high,size)'// Matrix slicing and blocks. All expressions listed here are read/write.
// Templated size versions are faster. Note that Matlab is 1-based (a size N
// vector is x(1)...x(N)).
// Eigen                           // Matlab
x.head(n)                          // x(1:n)
x.head()                        // x(1:n)
x.tail(n)                          // x(end - n + 1: end)
x.tail()                        // x(end - n + 1: end)
x.segment(i, n)                    // x(i+1 : i+n)
x.segment(i)                    // x(i+1 : i+n)
P.block(i, j, rows, cols)          // P(i+1 : i+rows, j+1 : j+cols)
P.block(i, j)          // P(i+1 : i+rows, j+1 : j+cols)
P.row(i)                           // P(i+1, :)
P.col(j)                           // P(:, j+1)
P.leftCols()                 // P(:, 1:cols)
P.leftCols(cols)                   // P(:, 1:cols)
P.middleCols(j)              // P(:, j+1:j+cols)
P.middleCols(j, cols)              // P(:, j+1:j+cols)
P.rightCols()                // P(:, end-cols+1:end)
P.rightCols(cols)                  // P(:, end-cols+1:end)
P.topRows()                  // P(1:rows, :)
P.topRows(rows)                    // P(1:rows, :)
P.middleRows(i)              // P(:, i+1:i+rows)
P.middleRows(i, rows)              // P(:, i+1:i+rows)
P.bottomRows()               // P(:, end-rows+1:end)
P.bottomRows(rows)                 // P(:, end-rows+1:end)
P.topLeftCorner(rows, cols)        // P(1:rows, 1:cols)
P.topRightCorner(rows, cols)       // P(1:rows, end-cols+1:end)
P.bottomLeftCorner(rows, cols)     // P(end-rows+1:end, 1:cols)
P.bottomRightCorner(rows, cols)    // P(end-rows+1:end, end-cols+1:end)
P.topLeftCorner()       // P(1:rows, 1:cols)
P.topRightCorner()      // P(1:rows, end-cols+1:end)
P.bottomLeftCorner()    // P(end-rows+1:end, 1:cols)
P.bottomRightCorner()   // P(end-rows+1:end, end-cols+1:end)// Of particular note is Eigen's swap function which is highly optimized.
// Eigen                           // Matlab
R.row(i) = P.col(j);               // R(i, :) = P(:, i)
R.col(j1).swap(mat1.col(j2));      // R(:, [j1 j2]) = R(:, [j2, j1])// Views, transpose, etc; all read-write except for .adjoint().
// Eigen                           // Matlab
R.adjoint()                        // R'
R.transpose()                      // R.' or conj(R')
R.diagonal()                       // diag(R)
x.asDiagonal()                     // diag(x)
R.transpose().colwise().reverse(); // rot90(R)
R.conjugate()                      // conj(R)// All the same as Matlab, but matlab doesn't have *= style operators.
// Matrix-vector.  Matrix-matrix.   Matrix-scalar.
y  = M*x;          R  = P*Q;        R  = P*s;
a  = b*M;          R  = P - Q;      R  = s*P;
a *= M;            R  = P + Q;      R  = P/s;R *= Q;          R  = s*P;R += Q;          R *= s;R -= Q;          R /= s;// Vectorized operations on each element independently
// Eigen                  // Matlab
R = P.cwiseProduct(Q);    // R = P .* Q
R = P.array() * s.array();// R = P .* s
R = P.cwiseQuotient(Q);   // R = P ./ Q
R = P.array() / Q.array();// R = P ./ Q
R = P.array() + s.array();// R = P + s
R = P.array() - s.array();// R = P - s
R.array() += s;           // R = R + s
R.array() -= s;           // R = R - s
R.array() < Q.array();    // R < Q
R.array() <= Q.array();   // R <= Q
R.cwiseInverse();         // 1 ./ P
R.array().inverse();      // 1 ./ P
R.array().sin()           // sin(P)
R.array().cos()           // cos(P)
R.array().pow(s)          // P .^ s
R.array().square()        // P .^ 2
R.array().cube()          // P .^ 3
R.cwiseSqrt()             // sqrt(P)
R.array().sqrt()          // sqrt(P)
R.array().exp()           // exp(P)
R.array().log()           // log(P)
R.cwiseMax(P)             // max(R, P)
R.array().max(P.array())  // max(R, P)
R.cwiseMin(P)             // min(R, P)
R.array().min(P.array())  // min(R, P)
R.cwiseAbs()              // abs(P)
R.array().abs()           // abs(P)
R.cwiseAbs2()             // abs(P.^2)
R.array().abs2()          // abs(P.^2)
(R.array() < s).select(P,Q);  // (R < s ? P : Q)// Reductions.
int r, c;
// Eigen                  // Matlab
R.minCoeff()              // min(R(:))
R.maxCoeff()              // max(R(:))
s = R.minCoeff(&r, &c)    // [s, i] = min(R(:)); [r, c] = ind2sub(size(R), i);
s = R.maxCoeff(&r, &c)    // [s, i] = max(R(:)); [r, c] = ind2sub(size(R), i);
R.sum()                   // sum(R(:))
R.colwise().sum()         // sum(R)
R.rowwise().sum()         // sum(R, 2) or sum(R')'
R.prod()                  // prod(R(:))
R.colwise().prod()        // prod(R)
R.rowwise().prod()        // prod(R, 2) or prod(R')'
R.trace()                 // trace(R)
R.all()                   // all(R(:))//检测矩阵中是否全为非零元素
R.colwise().all()         // all(R)
R.rowwise().all()         // all(R, 2)
R.any()                   // any(R(:))//检测矩阵中是否有非零元素,如果有,则返回1,否则,返回0。用法和all一样
R.colwise().any()         // any(R)
R.rowwise().any()         // any(R, 2)// Dot products, norms, etc.
// Eigen                  // Matlab
x.norm()                  // norm(x).    Note that norm(R) doesn't work in Eigen.
x.squaredNorm()           // dot(x, x)   Note the equivalence is not true for complex
x.dot(y)                  // dot(x, y)
x.cross(y)                // cross(x, y) Requires #include Type conversion
// Eigen                           // Matlab
A.cast();                  // double(A)
A.cast();                   // single(A)
A.cast();                     // int32(A)
A.real();                          // real(A)
A.imag();                          // imag(A)
// if the original type equals destination type, no work is done// Note that for most operations Eigen requires all operands to have the same type:
MatrixXf F = MatrixXf::Zero(3,3);
A += F;                // illegal in Eigen. In Matlab A = A+F is allowed
A += F.cast(); // F converted to double and then added (generally, conversion happens on-the-fly)// Eigen can map existing memory into Eigen matrices.
float array[3];
Vector3f::Map(array).fill(10);            // create a temporary Map over array and sets entries to 10
int data[4] = {1, 2, 3, 4};
Matrix2i mat2x2(data);                    // copies data into mat2x2
Matrix2i::Map(data) = 2*mat2x2;           // overwrite elements of data with 2*mat2x2
MatrixXi::Map(data, 2, 2) += mat2x2;      // adds mat2x2 to elements of data (alternative syntax if size is not know at compile time)// Solve Ax = b. Result stored in x. Matlab: x = A  b.
x = A.ldlt().solve(b));  // A sym. p.s.d.    #include
x = A.llt() .solve(b));  // A sym. p.d.      #include
x = A.lu()  .solve(b));  // Stable and fast. #include
x = A.qr()  .solve(b));  // No pivoting.     #include
x = A.svd() .solve(b));  // Stable, slowest. #include
// .ldlt() -> .matrixL() and .matrixD()
// .llt()  -> .matrixL()
// .lu()   -> .matrixL() and .matrixU()
// .qr()   -> .matrixQ() and .matrixR()
// .svd()  -> .matrixU(), .singularValues(), and .matrixV()// Eigenvalue problems
// Eigen                          // Matlab
A.eigenvalues();                  // eig(A);
EigenSolver eig(A);     // [vec val] = eig(A)
eig.eigenvalues();                // diag(val)
eig.eigenvectors();               // vec
// For self-adjoint matrices use SelfAdjointEigenSolver<>


